
Appearance
CAN protocol
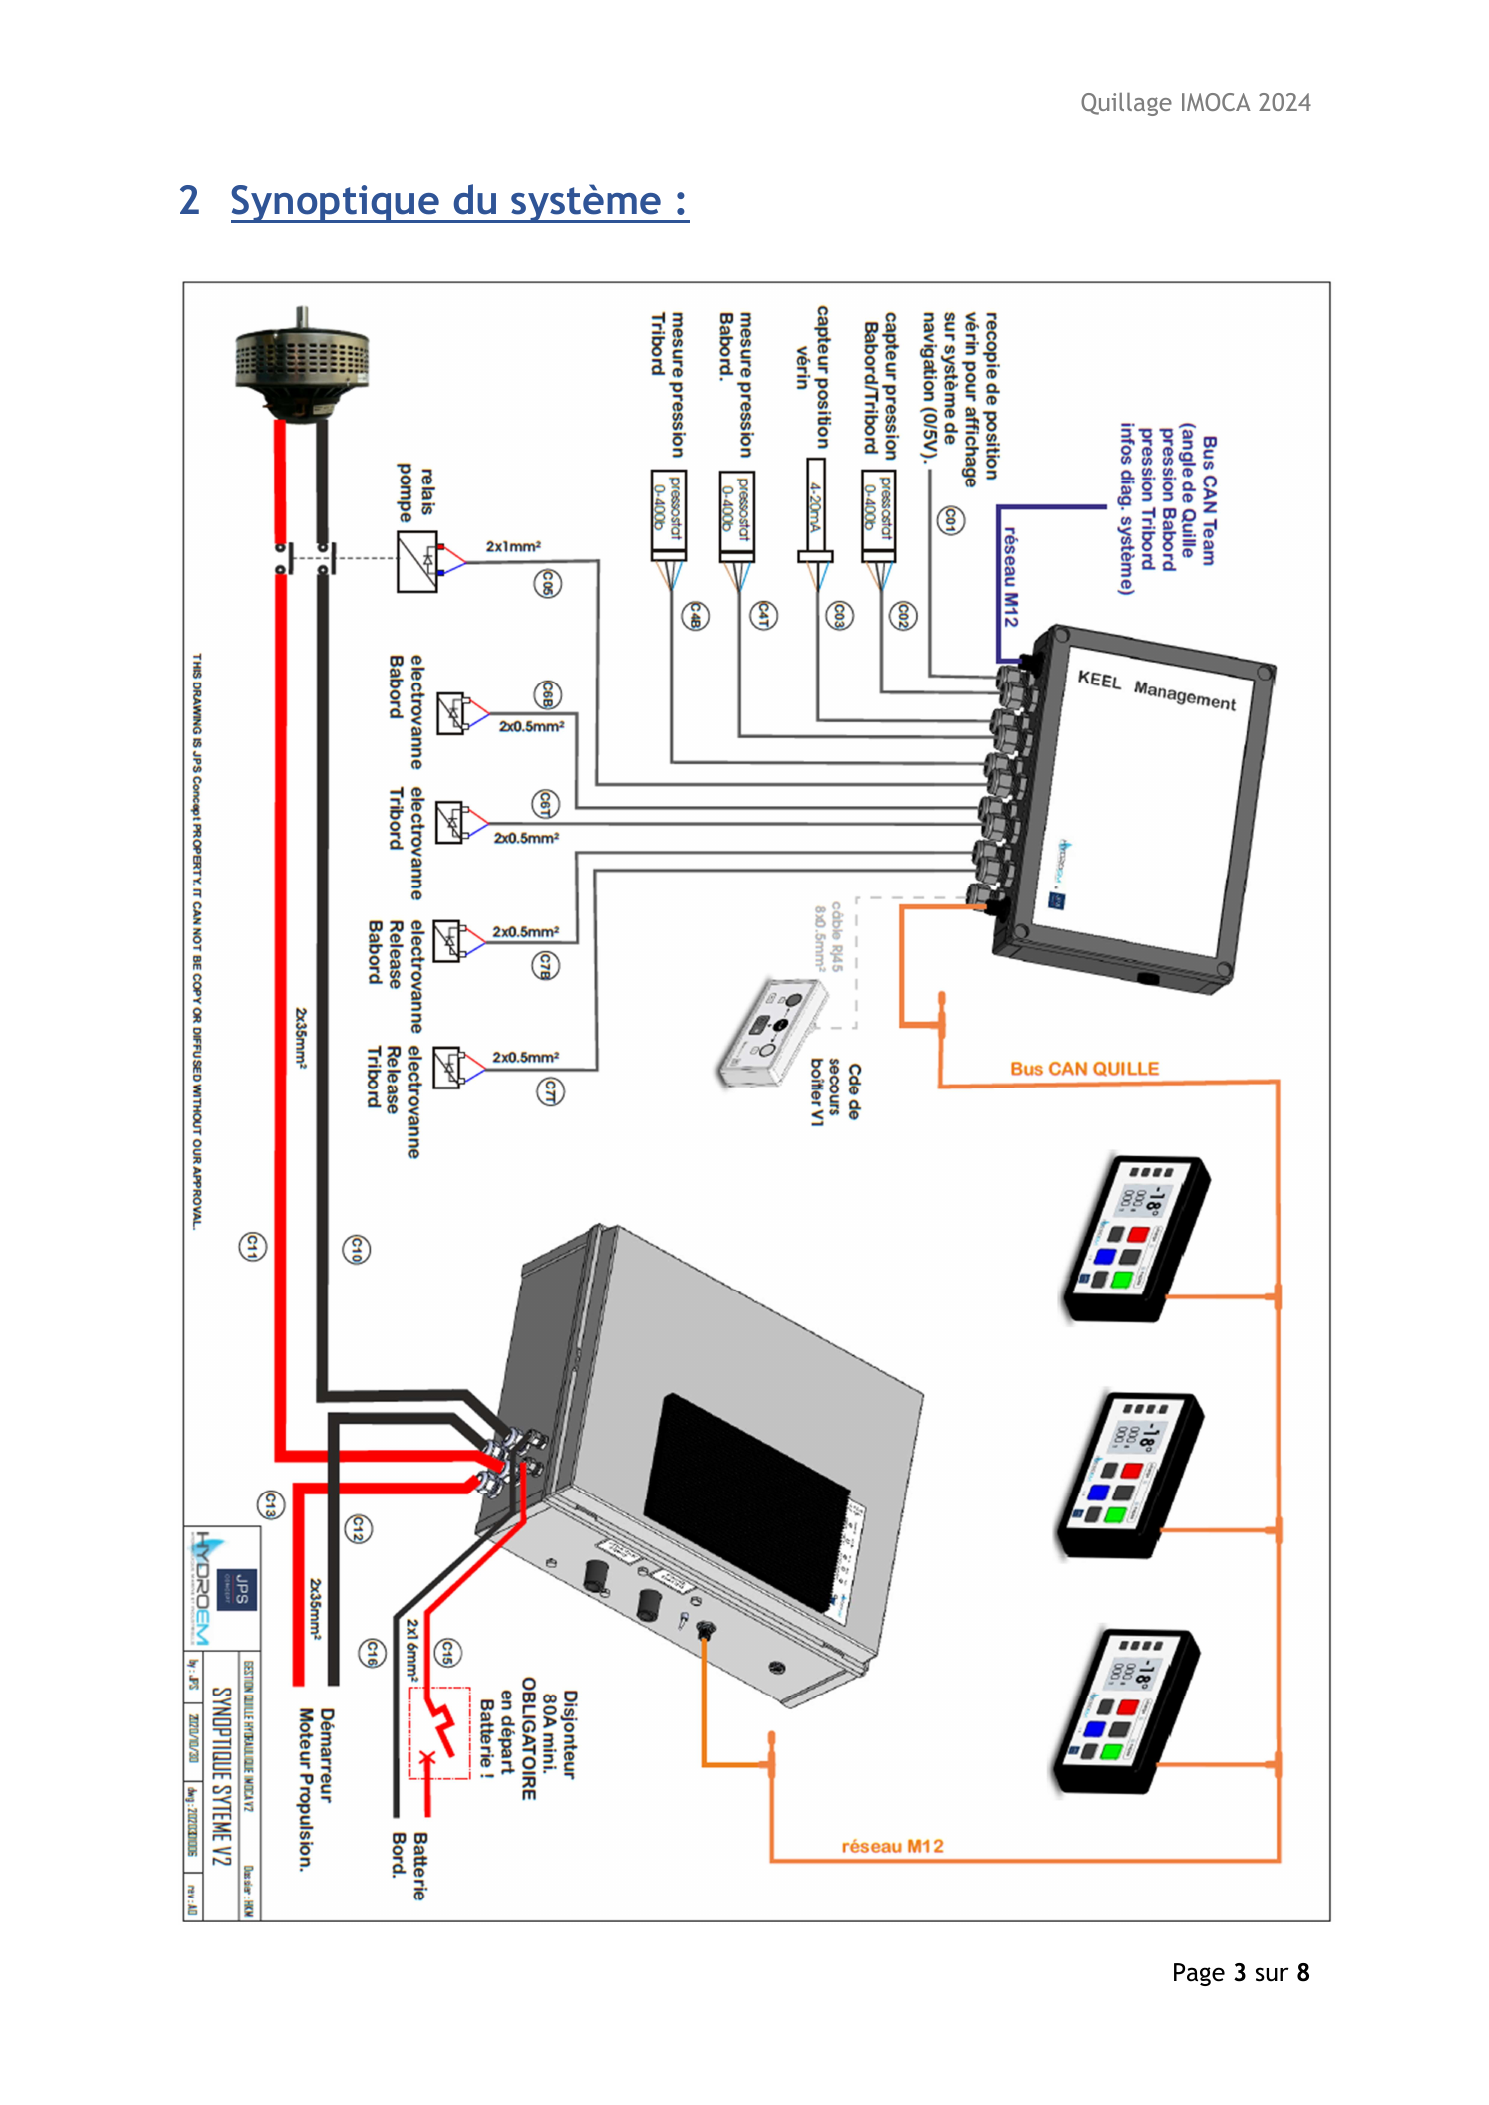
The KEEL Management box exposes its state on a dedicated CAN bus ("CAN équipe"). The bus is NMEA 2000-compatible at the physical level so that the same connectors can be used, but the application protocol is proprietary.
Bus parameters
| Parameter | Value |
|---|---|
| Standard | ISO 11898-1 (CAN 2.0A / 2.0B) |
| Baud rate | 250 kbit/s |
| Frame format | 2.0A — standard 11-bit identifiers |
| Termination | Not built in — installer must add 120 Ω plugs at both ends |
NMEA 2000 coexistence
The 250 kbit/s rate makes the bus compatible with NMEA 2000 wiring. Standard 11-bit IDs are used (NMEA 2000 uses 29-bit extended IDs), so the keel frames cannot perturb existing PGN traffic on a shared bus. The bit rate, frame format and frame IDs can be changed via a dedicated diagnostic interface (not from the façades) for integration into legacy installations. The encoding of fields described below is fixed and cannot be changed.
M12 connector
The bus is exposed on a 5-pin M12 NMEA 2000-compatible connector.
| Pin | Signal |
|---|---|
| 1 | Shield |
| 2 | +12 V |
| 3 | GND |
| 4 | CAN High |
| 5 | CAN Low |
Frames
Three frames are emitted, each with a periodicity of 1000 ms.
SYSTEM_STATE — 0x100
General system state.
| Field | Start (byte.bit) | Length (bit) | Type | Factor | Unit | Description |
|---|---|---|---|---|---|---|
RollUp | 1.4 | 4 | Uint | 1 | — | Continuous frame counter |
NbFsc | 1.2 | 2 | Uint | 1 | — | Number of façades connected (0..3) |
PresenceCapa | 1.0 | 1 | Bool | 1 | — | 0 — supercap absent1 — supercap present |
PosSensor | 2.0 | 1 | Bool | 1 | — | 0 — sensor absent1 — sensor present |
PortPresSensor | 2.1 | 1 | Bool | 1 | — | 0 — sensor absent1 — sensor present |
StrdPresSensor | 2.2 | 1 | Bool | 1 | — | 0 — sensor absent1 — sensor present |
OVLO | 2.3 | 1 | Bool | 1 | — | Over Voltage Lock Out.0 — battery voltage OK1 — battery voltage too high |
UVLO | 2.4 | 1 | Bool | 1 | — | Under Voltage Lock Out.0 — battery voltage OK1 — battery voltage too low |
CCEvRelPort | 2.5 | 1 | Bool | 1 | — | Port release valve short circuit.0 — OK1 — short |
CCEvRelStar | 2.6 | 1 | Bool | 1 | — | Starboard release valve short circuit.0 — OK1 — short |
CCEvMouvPort | 2.7 | 1 | Bool | 1 | — | Port movement valve short circuit.0 — OK1 — short |
CCEvMouvStar | 3.0 | 1 | Bool | 1 | — | Starboard movement valve short circuit.0 — OK1 — short |
CCCmdMotor | 3.1 | 1 | Bool | 1 | — | Motor relay drive short circuit.0 — OK1 — short |
KEEL_STATE — 0x101
Keel state.
| Field | Start (byte.bit) | Length (bit) | Type | Factor | Unit | Description |
|---|---|---|---|---|---|---|
RollUp | 1.0 | 4 | Uint | 1 | — | Continuous frame counter |
InvPressure | 1.4 | 1 | Bool | 1 | — | Pressure inversion (the keel generates lift).0 — keel generates righting torque (normal)1 — keel generates lift (inverted) |
KeelAngle | 2.0 | 16 | Int | 0.1 | ° | Current keel angle, range −38° .. +38°. Negative = port, positive = starboard. |
PortPressure | 4.0 | 8 | Uint | 2 | bar | Pressure in the port (cylinder nose) chamber. |
StarboardPressure | 5.0 | 8 | Uint | 2 | bar | Pressure in the starboard (cylinder rod) chamber. |
InvPressure note
Because of the cylinder geometry, a pressure inversion does not map directly to the chamber pressure values. Use InvPressure rather than comparing PortPressure and StarboardPressure.
CAPA_STATE — 0x102
Supercapacitor state.
| Field | Start (byte.bit) | Length (bit) | Type | Factor | Unit | Description |
|---|---|---|---|---|---|---|
RollUp | 1.0 | 4 | Uint | 1 | — | Continuous frame counter |
VBat | 2.0 | 16 | Uint | 0.1 | V | Battery voltage |
VCapa | 4.0 | 16 | Uint | 0.1 | V | Supercapacitor voltage |
ICapa | 6.0 | 16 | Int | 0.1 | A | Supercapacitor current |